
A model with an enabled Physics Zone switches physics on by itself. For a model without zones, switch it on under Settings → Simulation → Physics (whole scene); it takes effect on the next model load.
With physics off, conveyors alone move the parts. Parts follow the belt, queue up and stop at the end of a line. With physics on, a part that leaves a conveyor becomes a physical body. It falls, slides down a chute, tips over and stacks in a bin.
Moving machine parts can push these bodies, and the parts they carry contribute to the load on the drive.
Physics Zone
Section titled “Physics Zone”A Physics Zone limits physics to one area of the model, for example a hopper, a chute or a bin. Free parts inside its box become physical bodies that fall, slide, tip and stack. A part returns to transport once it rests upright on a conveyor, or travels on as the load of a container that carries it out. Parts held by a gripper or carried as a load stay with their carrier. A model with an enabled Physics Zone switches physics on by itself, so a delivered link works without the Physics (whole scene) setting.
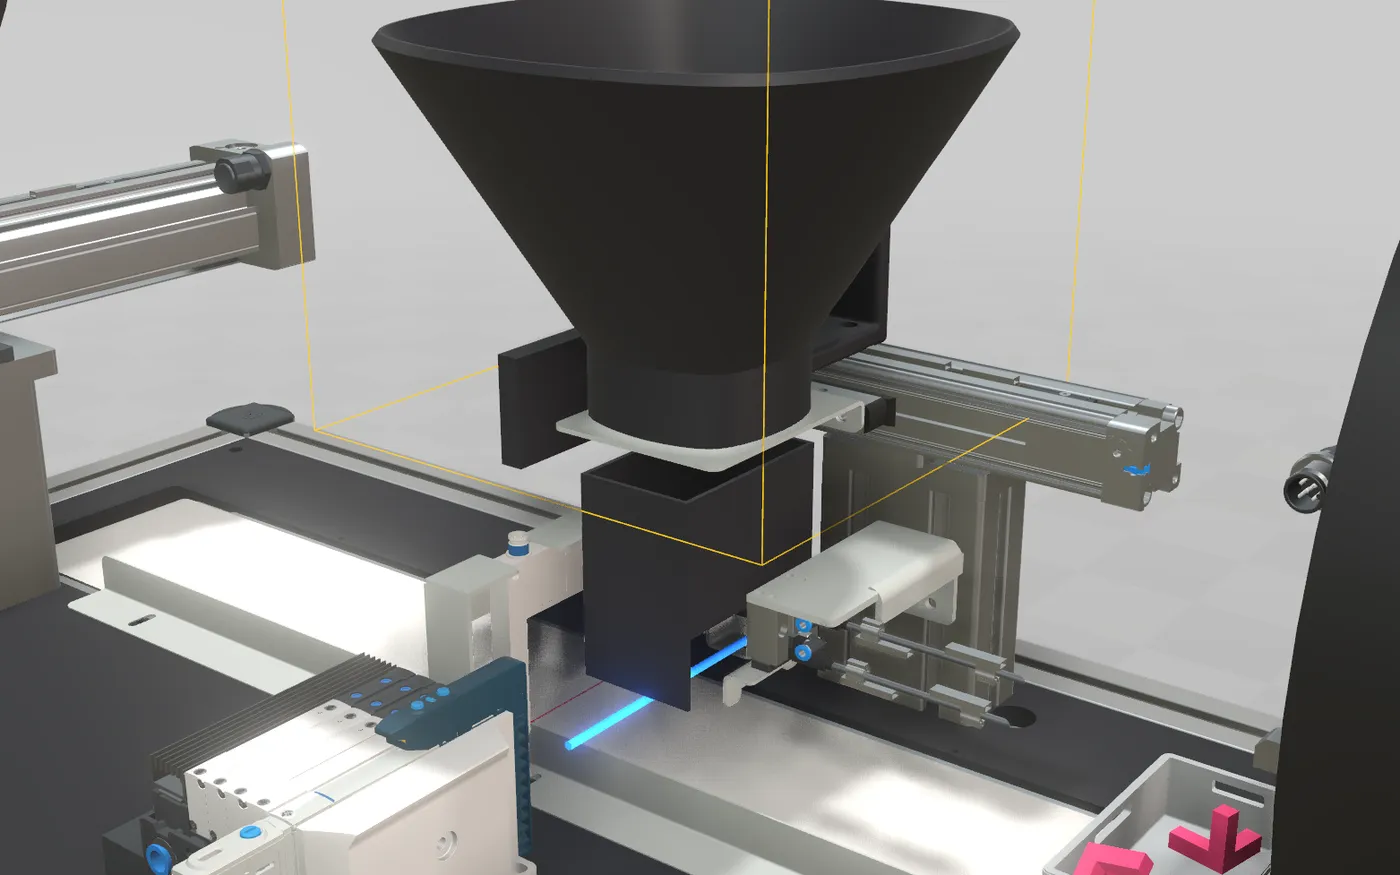
The yellow wireframe shows the zone. In the Festo demo cell it encloses the hopper, the chute and the filling station, where the logo parts fall into the boxes. The MU page shows the same station in a section view.
In the Asset Editor, select the node and choose Quick Edit → Components → Physics Zone. The editor adds a 1 × 1 × 1 m Box Collider to the same node if it has none and keeps an existing one; its center and size set the zone volume.
| Setting | Unit | Default | What it does |
|---|---|---|---|
| ZoneEnabled | on | Switches physics on inside this zone | |
| WholeScene | off | Ignores the box and makes the whole scene the zone | |
| Friction | 0.8 | Friction of the parts inside the zone. For a chute, keep it below tan(tilt), e.g. 0.58 at 30°, so parts slide | |
| Restitution | 0 | How much parts bounce; 0 means not at all | |
| SoftCcdPrediction | m | 0.03 | Look-ahead that reduces the risk of fast parts passing through thin floors and walls; 0 to 0.2, 0 switches it off |
| RemoveBelowY | m | -10 | Parts that fall below this world height are removed |
| ShowGizmo | on | Shows the zone as a wireframe box | |
| StaticColliders | empty | Additional fixed geometry the parts collide with, such as chute walls or bins | |
| LimitToLayers | empty | Only parts on one of these layers become physical. Empty means all parts; a part without a layer does not match a list |
Where zones overlap, the first zone wins; settings are never mixed. Drop Detection ignores parts controlled by physics, because falling is intended there.
Moving parts push, lift and carry
Section titled “Moving parts push, lift and carry”Any part the twin moves itself takes part in physics as soon as physics is on. This includes parts on a drive axis and links of a mechanism. A pusher pushes a box off the line. A lift table lifts what stands on it. A gripper pad carries a part from one station to the next, and lets go when it opens.
A moving part needs a collider. Author a Box Collider or a Mesh Collider on it in Unity. Unlike fixed scenery, a moving part has no automatic fallback to its bounding box. An estimated box on a gripper finger could misrepresent its contact geometry without warning, so parts without colliders stay passive.
What the two collider types become:
| Authored | What the physics sees |
|---|---|
| Box Collider | The box, with its offset, rotation and scale as authored. |
| Mesh Collider | The convex hull of the shape, like shrink-wrap around it. Pockets, slots and forks are filled in. |
A hull is used even when the mesh is authored as concave; the message log says so. If a fork or a pocket has to grip something, model that region as its own box collider rather than relying on the mesh.
Colliders marked disabled or is trigger in Unity stay out of the physics, exactly as elsewhere.
The payload shows up in the drive forces
Section titled “The payload shows up in the drive forces”When a mechanism link carries a part, its weight is measured at the contact and used in the mechanism’s force analysis. Open Quick Edit → Mechanism → Forces while the machine is running to see drive figures for the loaded machine. The peak and RMS values used for motor sizing include the part.
An extra column, Ext. load, appears in the same table as soon as any link carries something. It shows the force in newtons measured on that link in the previous simulation step. The column disappears when no link carries anything, rather than displaying dashes.
Part weight. A part weighs 1 kg by default. Set a different weight per part through the part’s PhysicsMassKg field. Without a specified weight, the physics engine would assign about 8 grams to a 200 mm cube, making payload figures unreliable.
Small parts and thin floors. A small part that falls onto a thin floor can pass straight through it in a single simulation step. Every physics zone therefore looks ahead a short distance for each falling part. You set that distance in the zone’s Soft CCD Prediction field, in metres. The default is 0.03 m (30 mm); the allowed range is 0 to 0.2 m, and 0 switches the look-ahead off. In a test with 26 mm parts dropped onto a 15 mm floor, 20 of 300 parts fell through without the look-ahead and none with the default. Raise the value only if fast parts still fall through a floor.
What this does not do yet
Section titled “What this does not do yet”Account for these limitations before using the figures to select a drive:
- Friction from stacked parts is not passed down. If a part rests on another part, its weight reaches the link correctly. The friction it exerts on the part beneath it does not travel further down. A sliding stack therefore under-reports the sideways load.
- A tipping part’s spin is ignored. Its contact forces and their lever arms are counted; the rotational inertia of the tipping itself is not.
- The load is one simulation step old. Physics runs after the mechanism each step. A load measured now reaches the force analysis on the next step. This delay is invisible at 60 steps per second, but a hard impact appears one step late.
- Parts that drive into a zone later. If the model uses explicit physics zones, each machine part is assigned to a zone when the model loads. A part that only later travels into another zone will not collide there. This limitation does not apply to the default whole-scene zone.
- Physics never moves the mechanism. A mechanism always follows its drives and joints. A load can raise the force a drive has to produce; it can never bend, stall or drag the machine. The same motion without any parts produces exactly the same poses.
Checking that it is working
Section titled “Checking that it is working”The Simulation settings tab shows a small diagnostics line while physics is running, for example:
2 zones / 17 bodies (4 kinematic) / 0.4 ms stepBodies are the free parts; kinematic are the moving machine parts. If a gripper visibly travels through a part, check the kinematic count first. No kinematic bodies means no colliders were authored on the moving parts. In that case, the parenthesis is absent.
See also
Section titled “See also”- Settings — where physics is switched on
- Rigid-Body Mechanisms — the force analysis the payload feeds into
- Collision Detection — geometric collision notices, which work independently of physics
- Multi-Model Simulation — how physics, 2D zones, kinematics and DES fit together