
Universal Robots UR10
In this ModelZoo scene, a Universal Robots UR10 robot picks up pumpkins from an entry conveyor and loads them into boxes arriving on an exit conveyor. The robot is integrated via the realvirtual.io Universal Robots Interface using TCP/IP.
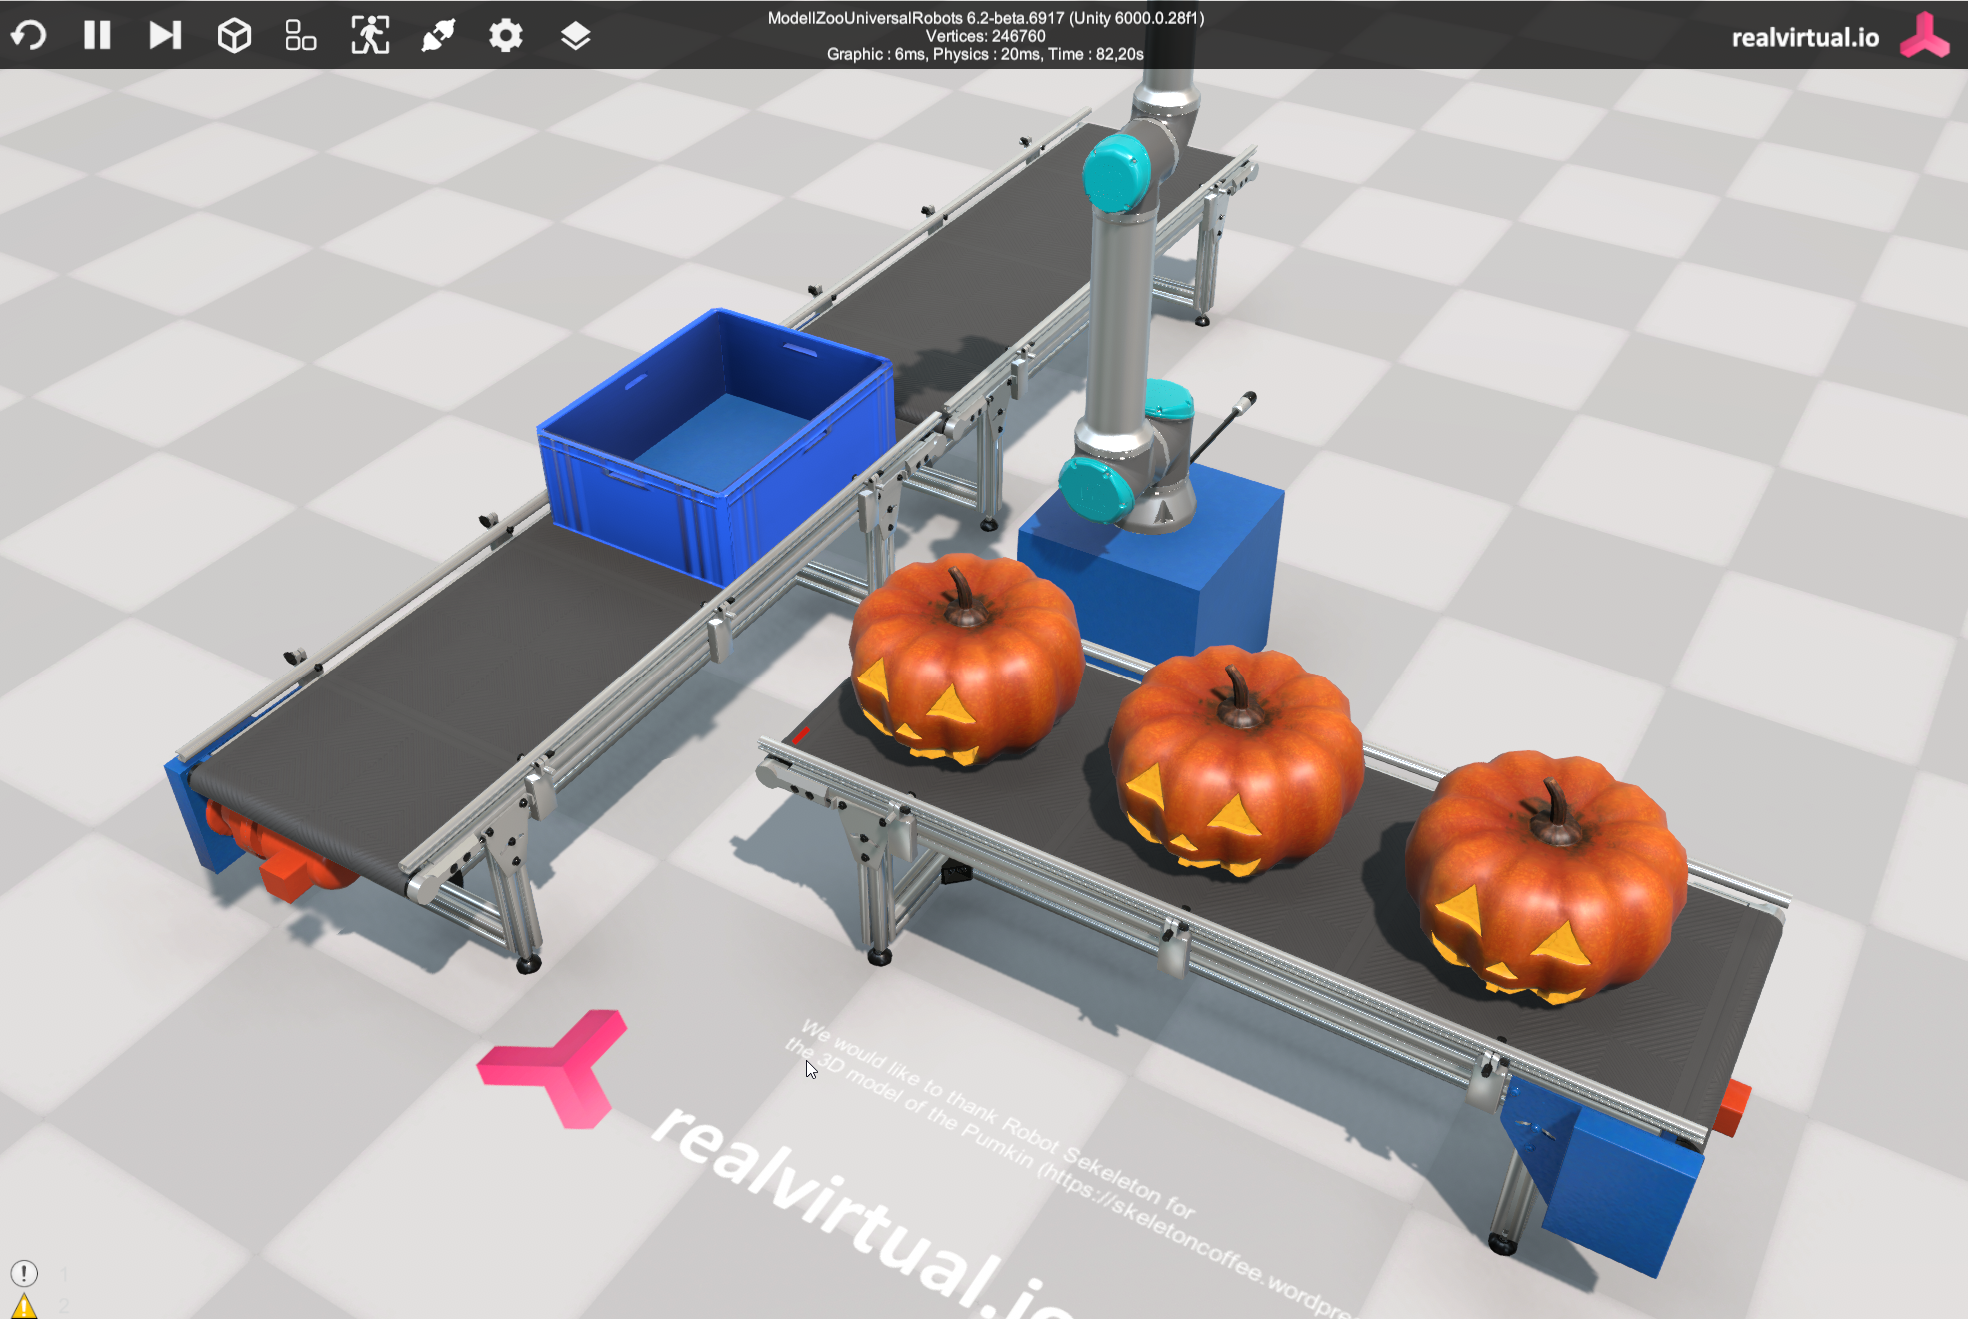
Universal Robots modelzoo scene
All logic for conveyor control is handled within the simulation. The robot must be programmed to react to and control digital I/O signals as listed below.
You need to install URSIM as a virtual machine on your computer.
Interface Configuration
Section titled “Interface Configuration”To establish communication, open the ⚙️ Settings panel in the top menu bar and enter the IP address of your URSIM installation.
Make sure:
- URSIM is running and reachable at the specified IP address
- Network access is allowed (firewall, network access to the virtual machine and routing configured correctly)
- The I/O signals match the configuration in your robot program
Signal Mapping
Section titled “Signal Mapping”Digital Outputs (Robot → Simulation)
| Signal | Address | Description |
|---|---|---|
CloseGripper | DO[0] | Robot command to close the gripper |
RobotMoving | DO[1] | Robot is currently moving |
BoxLoaded | DO[2] | Robot signals that a box has been loaded |
Digital Inputs (Simulation → Robot)
| Signal | Address | Description |
|---|---|---|
LoadAvailable | DI[0] | Simulation signals a pumpkin is ready to load |
BoxAvailable | DI[1] | Simulation signals a box is in position |