
GripTarget
Overview
Section titled “Overview”GripTarget marks a precise placement position for the Grip component’s Auto-Place system. When a Grip releases an MU near a GripTarget, the MU aligns to the target’s position and rotation and becomes a child of the GripTarget.
GripTarget is a passive marker — it does not detect MUs on its own. The Grip component finds it using an OverlapSphere search within the configured Grip Target Search Radius.
Properties
Section titled “Properties”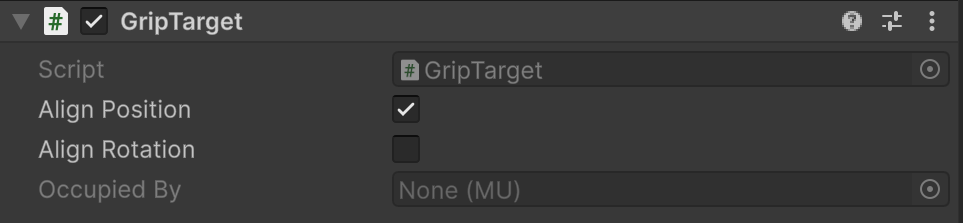
GripTarget Inspector
Align Position (boolean) Snaps the MU position to the GripTarget’s world position on placement. Default: true.
Align Rotation (boolean) Snaps the MU rotation to the GripTarget’s rotation on placement. Default: false.
Occupied By (MU, read-only) Shows which MU is currently placed at this target. Empty means the target is free and available for placement.
- Add a GripTarget component to a GameObject at the desired placement position
- Position and rotate the GameObject to define where and how the MU should land
- Configure the Grip component with Place Mode = Auto
- Set Grip Target Search Radius on the Grip to control the detection range (default: 500 mm)
- When the Grip places an MU within range, it automatically snaps to the nearest free GripTarget
The MU becomes a child of the GripTarget transform, so if the GripTarget moves (e.g., on a conveyor or robot), the placed MU moves with it.
GripTarget vs Fixer
Section titled “GripTarget vs Fixer”Both components handle MU placement, but serve different purposes:
| GripTarget | Fixer | |
|---|---|---|
| Purpose | Passive placement slot (“parking spot”) | Active station lock (“parking gate with lock”) |
| Needs Grip? | Yes, always — only works with Grip component | No — works standalone |
| MU arrives how? | Grip places it | Conveyor, AGV, or robot delivers it |
| Controlled by | Grip component logic | PLC signals (FixerFix/FixerRelease) or auto-mode |
| Detection | None — found by Grip’s OverlapSphere | Own BoxCollider trigger or Raycast |
| MU parenting | MU becomes child of GripTarget | MU becomes child of Fixer (restored to previous parent on release) |
| Multi-MU | One MU per target | Multiple MUs via MUSFixed list |
| Handover blocking | No | Yes — prevents double-fixing between stations |
| Tag filtering | No | Yes — only fix specific part types |
Use GripTarget when a Grip (robot gripper) places MUs at predefined positions. Use Fixer when MUs arrive on their own (conveyor) and need to be stopped/held by PLC control.