Virtual commissioning software: test PLC code before machine assembly
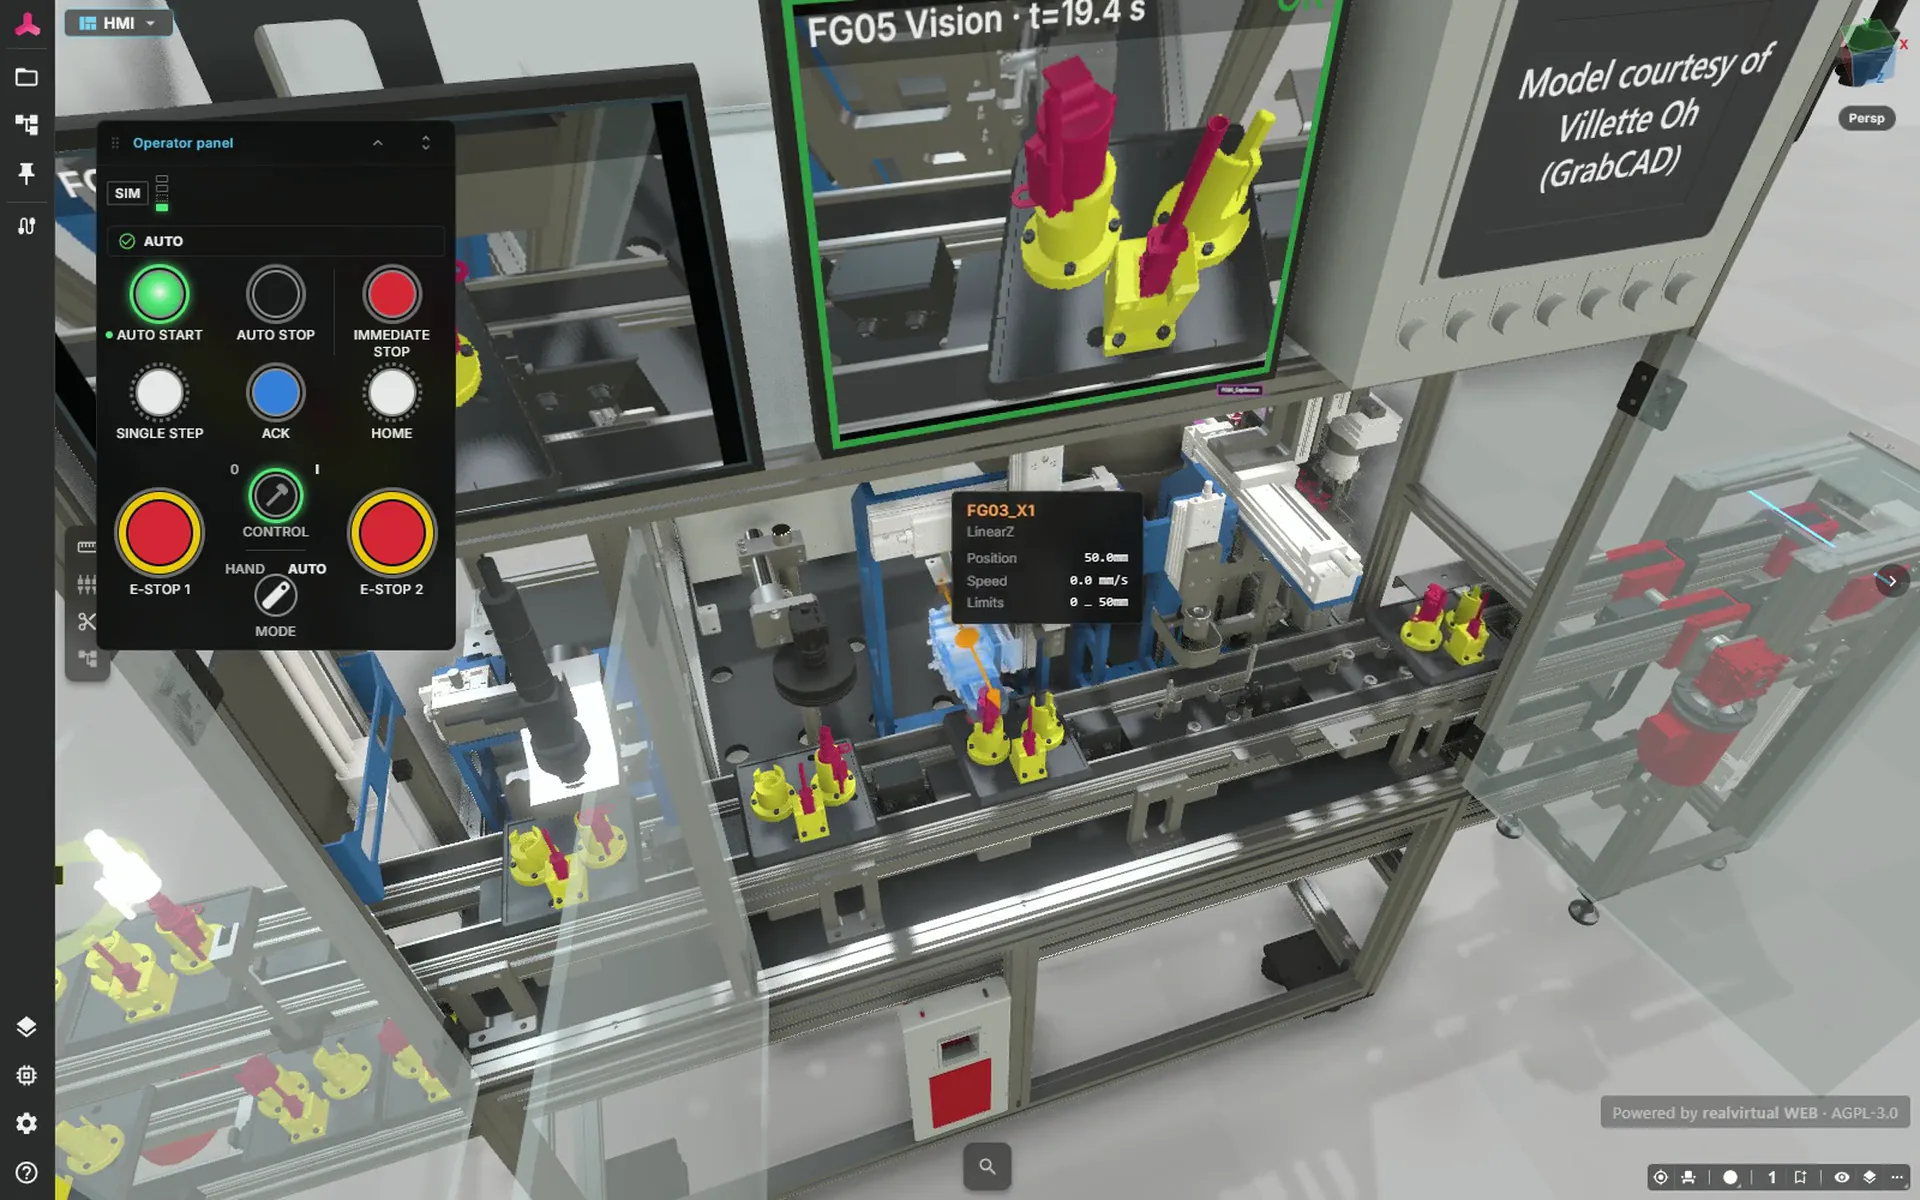
Test your PLC code against the simulated machine before the hardware exists. Open the laser welding station with its virtual PLC directly in the browser and inspect its sequence.
What virtual commissioning software does
In virtual commissioning, the real controller – PLC or robot controller – is commissioned against a simulated machine model. Drives, sensors and material flow behave like the real plant; the automation code runs unchanged. Errors in sequence logic, interlocks and signals surface while they can still be fixed at the desk – not on site.
In the digital twin lifecycle this is the second of four stages: the sales and concept simulation becomes the virtual commissioning model, later the integration test with MES, and finally the 3D HMI on the running machine. One model, built once, reused across all stages.
Traditional vs. virtual commissioning
In traditional commissioning, the control code meets the mechanics for the first time at the real machine – errors surface on site, under schedule pressure. With virtual commissioning this happens weeks earlier: on the digital twin, with no downtime and no risk to the hardware.
| Traditional | Virtual | |
|---|---|---|
| Errors in PLC code | only surface at the real machine | are found on the model – before assembly |
| Test coverage | only what the hardware allows | any scenario, including faults and edge cases |
| On-site commissioning | full scope including software debugging | up to 75% shorter |
| Risk | crashes and mechanical damage possible | Tests without mechanical damage to the real machine |
The 75 percent figure refers to the TU Munich field study by Zäh/Wünsch. On-site commissioning time fell by 75 percent, while control functions working correctly on the first attempt rose from 37 to 84 percent. This is not a guaranteed outcome for every project.
In practice: SEW-EURODRIVE
"Unity’s open ecosystem makes virtual commissioning scalable. High-fidelity visualization, CAD integration, and real-time physics, helps us create realistic digital twins to optimize automation, enabling faster, safer, more efficient commissioning."

Made in Germany – and verifiably open
realvirtual is developed in Germany, with more than 18 years of automation experience. The technology is open to inspection: realvirtual Unity Plugin Professional ships with full C# source code. The handover format is open GLB, and the AGPL-licensed delivery viewer is on GitHub.
For the EU Machinery Regulation 2027 this means: we answer the obligation to keep digital documentation available over the machine’s lifetime with architecture instead of a contract – open formats and an open-source viewer cannot be taken away from you.
Build and test models with AI
Use the AI window in realvirtual through realvirtual CONNECT with your local Claude Code or Codex; your current selection provides context. The open MCP server also lets you connect your own agents to create components, map PLC tags to model signals using their comments, write and start ST programs, build control panels and run simulations.
AI can assist with model setup, programming and simulation. You remain responsible for checking and approving the result; AI is optional and requires your own AI access.
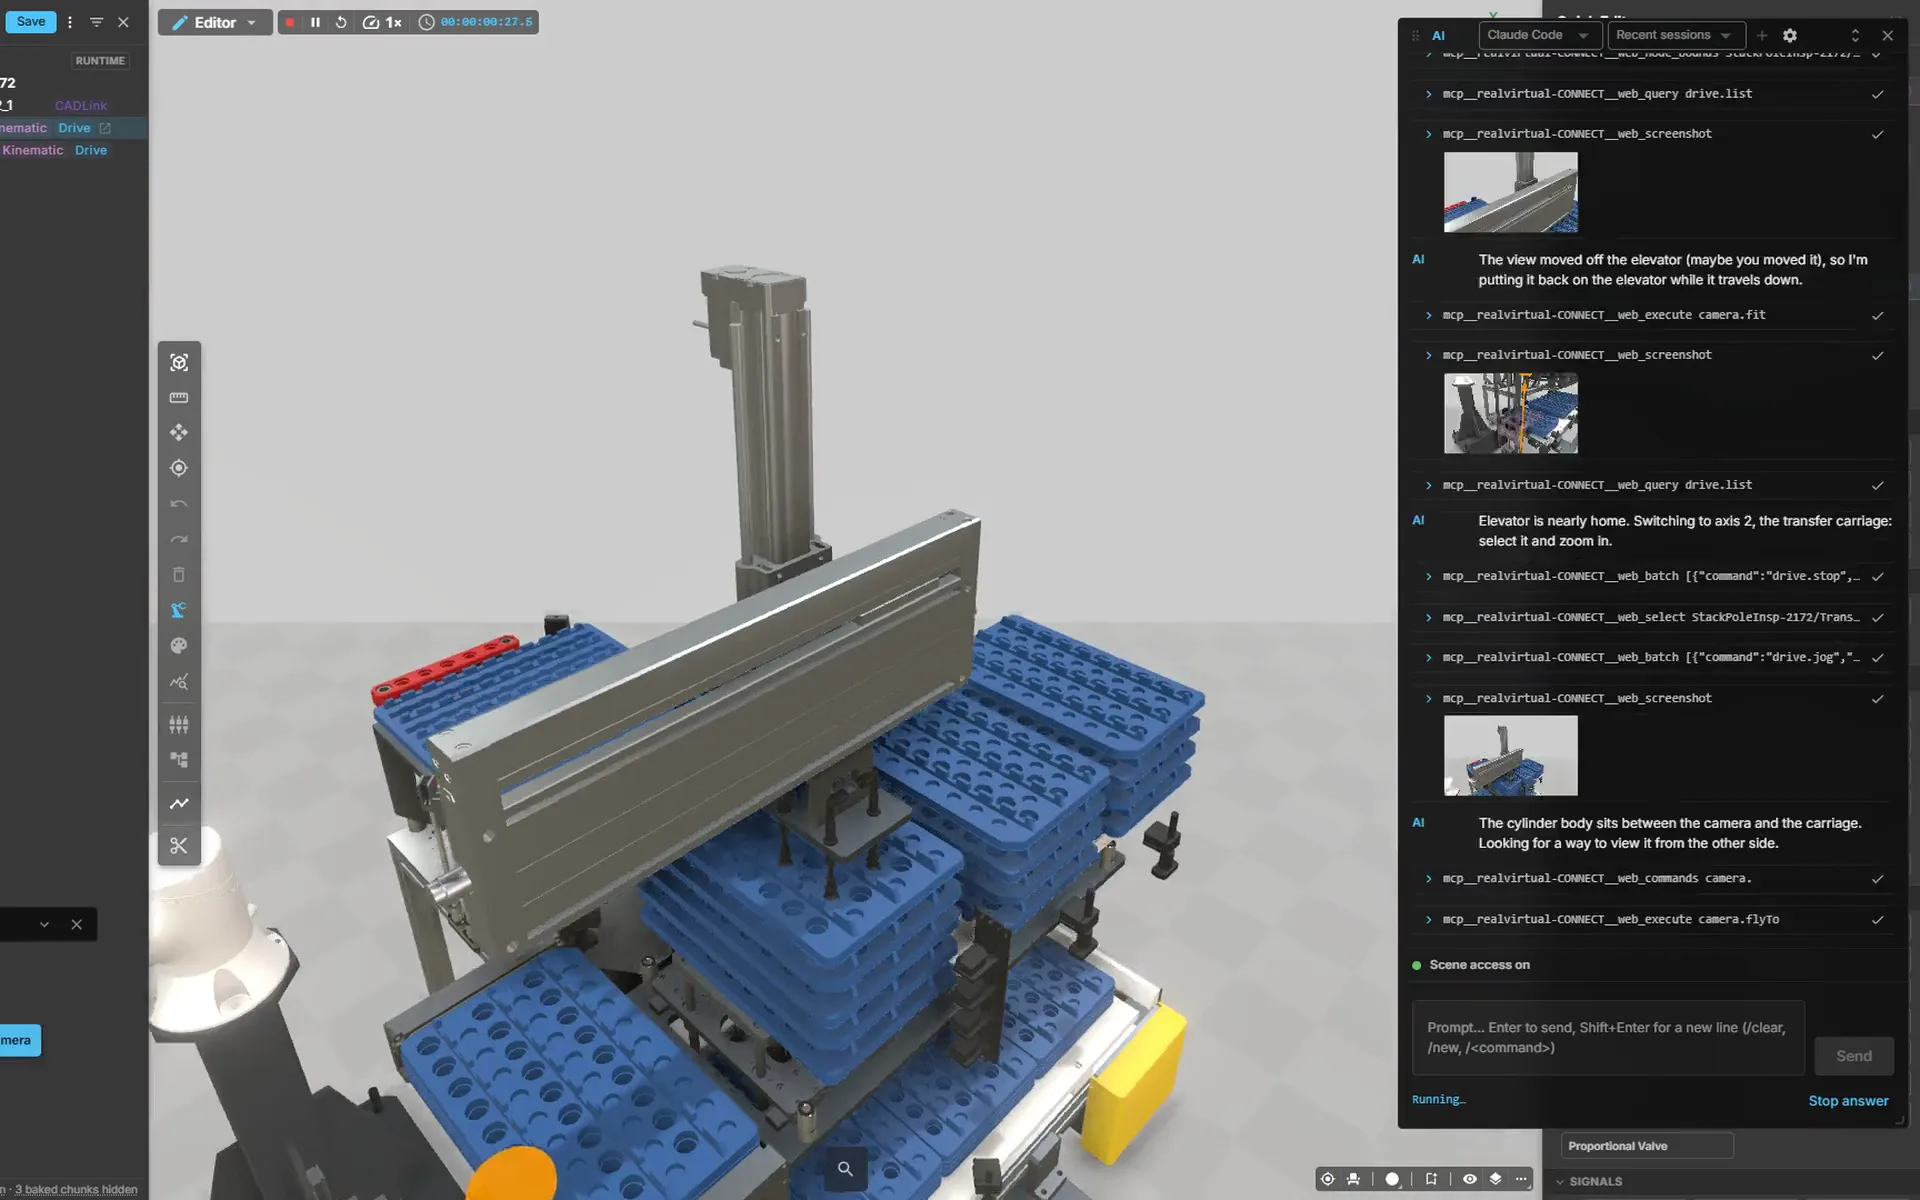
Deep dive: Virtual Commissioning AI – AI agents and vision AI in the digital twin →
Runs on your machine – not in the cloud
The simulation runs locally on the engineering PC. There is no GPU farm, no data center, no streaming infrastructure and no forced cloud – your machine data and CAD models never leave your company.
Deployment is royalty-free as standalone applications for Windows, Linux, macOS and more. In addition, documentation and machine models reach your customers as GLB in the browser – free, no installation, no account.
SiL or HiL? The terms in short
Virtual commissioning runs in different configurations – the difference is where the control code executes.
Software-in-the-Loop (SiL)
The controller runs as a software simulation – such as Siemens PLCSim Advanced or TwinCAT on the same PC. No hardware needed, scales freely, ideal for early testing. realvirtual connects directly to PLCSim Advanced, SIMIT and TwinCAT.
Hardware-in-the-Loop (HiL)
The real PLC hardware is connected to the simulated machine model over the network – e.g. an S7-1500 via S7-TCP or a Beckhoff IPC via ADS. The controller’s real timing is part of the test; typical cycle times of 10–50 ms are sufficient for smooth motion.
Model-in-the-Loop (MiL)
Control and behavior models from MATLAB/Simulink couple directly to the twin via FMI – for drive and process models before the first line of PLC code exists.
How virtual commissioning works: five steps
From the CAD model to the acceptance test, a project almost always follows the same order. The effort sits mainly in steps 2 and 3, the payoff in steps 4 and 5.
1. Import the CAD data
The design data is imported, for example as STEP or JT, and simplified for real-time simulation. Small parts without a function are dropped, moving assemblies stay separate.
2. Add kinematics
Axes, drives, sensors, grippers and conveyors are defined. Plain geometry becomes a machine that moves the way the real one does.
3. Connect the signals
The model's inputs and outputs are mapped to the controller's variables, whether Siemens S7, Beckhoff TwinCAT or OPC UA. From here on the PLC sees the model like the real plant.
4. Test
The controller runs the simulated machine, first as software-in-the-loop, later with the real PLC. Sequences, interlocks, faults and edge cases are played through, including ones you would never risk on the real machine.
5. Reuse
After acceptance the model stays in use: as a 3D HMI on the running machine, for training and service, and as the starting point for retrofits.
What to look for when choosing the software
Virtual commissioning software differs less in the simulation core than in what happens before and after it. These six questions help with the comparison.
Interfaces
Are your PLCs and robots supported directly, both as software simulation (PLCSim Advanced, TwinCAT) and with real hardware?
Open data format
Can the model be opened outside the tool, for sales, the operator interface or documentation? Or does every viewer need a license?
Price and licensing
Are prices public? Are there runtime fees for delivered machines, and does the license expire when a subscription ends?
Getting started
Is there a free edition you can test on your own model before you need a quote?
Extensibility
Can you add your own components and logic, through source code or a documented API, instead of waiting for the vendor's roadmap?
Operation
Does the simulation run locally on a standard engineering PC, or does it need a cloud, a data center or special graphics hardware?
Your controller is supported
realvirtual CONNECT connects your digital twin in the browser to the real controller using the same signal mapping, via MQTT, OPC UA, Siemens S7 including PLCSIM Advanced, Beckhoff TwinCAT ADS, Modbus TCP Client/Server, EtherNet/IP, Bosch Rexroth ctrlX, Keba Kemro X, Festo AX, FANUC or Denso. More than 25 interfaces are additionally available for the realvirtual Unity Plugin.
Demo models to try
Open the models in the Public Demo, without an account or installation.
Laser welding assembly station
Explore five stations, two lifts, a return conveyor and 14 pallets, controlled by 11 ST programs on the virtual PLC using the station’s actual variable list. Select operating modes and use the emergency stop on the control panel in a model ready for virtual commissioning.
Open in the demo ↗ (opens in a new tab)Delta picker with SEW drives
Explore a three-axis delta robot programmed in ST with MC_MoveLinearAbsolute, with SEW servo motors, live motor torque and an axis forces window. Try the control panel’s speed override, cycle counter and emergency stop, and open the operating manual attached to the motors as a PDF.
Open in the demo ↗ (opens in a new tab)
Transparent pricing
realvirtual Unity Plugin Professional, per concurrent developer – no runtime fees for delivered applications. Getting started is free: realvirtual Unity Plugin Starter with the Siemens S7 interface on the Unity Asset Store.
Requires a valid Unity license (not included). realvirtual Commercial includes the realvirtual Unity Plugin in the Starter and Professional variants as downloads. realvirtual Unity Plugin Professional is also available separately, without realvirtual Commercial. realvirtual Commercial itself does not require Unity — the twin is authored in the browser.
Frequently asked questions about virtual commissioning
What does virtual commissioning software cost?
realvirtual Unity Plugin Starter is free (including the Siemens S7 interface). realvirtual Unity Plugin Professional costs €1,250 net, one-time per developer – with no runtime fees for delivered applications. All prices are published on the website. realvirtual Commercial includes the realvirtual Unity Plugin in the Starter and Professional variants. Obtain the Unity Editor licence separately from Unity. Professional is also available on its own; the browser application does not require Unity.
Which controllers are supported?
25+ interfaces: Siemens S7 and PLCSim Advanced, Beckhoff TwinCAT, OPC UA, MQTT, Modbus, EtherNet/IP, Bosch ctrlX, Keba, plus robot controllers from KUKA, Fanuc, ABB, Universal Robots and more – and FMI/Simulink for external behavior models.
What is the difference between SiL and HiL?
With Software-in-the-Loop (SiL) the controller runs as a simulation (e.g. PLCSim Advanced) on the PC; with Hardware-in-the-Loop (HiL) the real PLC is connected over the network. realvirtual supports both with the same signals – from early SiL testing to the HiL acceptance test.
What virtual commissioning software is available?
Roughly three groups: simulation modules from the large automation and PLM vendors, specialized tools focused on hardware-in-the-loop and real time, and open platforms. realvirtual belongs to the third group: it runs in the browser, with full source code and an open GLB format; teams who want to work in the Unity Editor use the realvirtual Unity Plugin. Which group fits depends mainly on whether the model should be reused after commissioning.
Can I read the source code?
Yes. realvirtual Unity Plugin Professional ships with full C# source code; the realvirtual browser viewer is open source (AGPL) on GitHub. The GLB handover format is openly documented.
Do I need a cloud or special hardware?
No. The simulation runs locally on a standard engineering PC. No GPU farm, no data center and no cloud connection is required; your data stays in-house.
How does virtual commissioning relate to the digital twin?
Virtual commissioning is the second of four digital twin stages: concept simulation, virtual commissioning with the real controller, integration testing with MES, and the 3D HMI on the running machine – the same model is reused across all stages.
See it running
Open the live demo in your browser, without installation or an account. The Community core is available on GitHub under AGPL-3.0.